Water
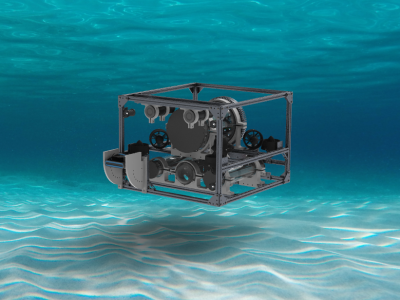
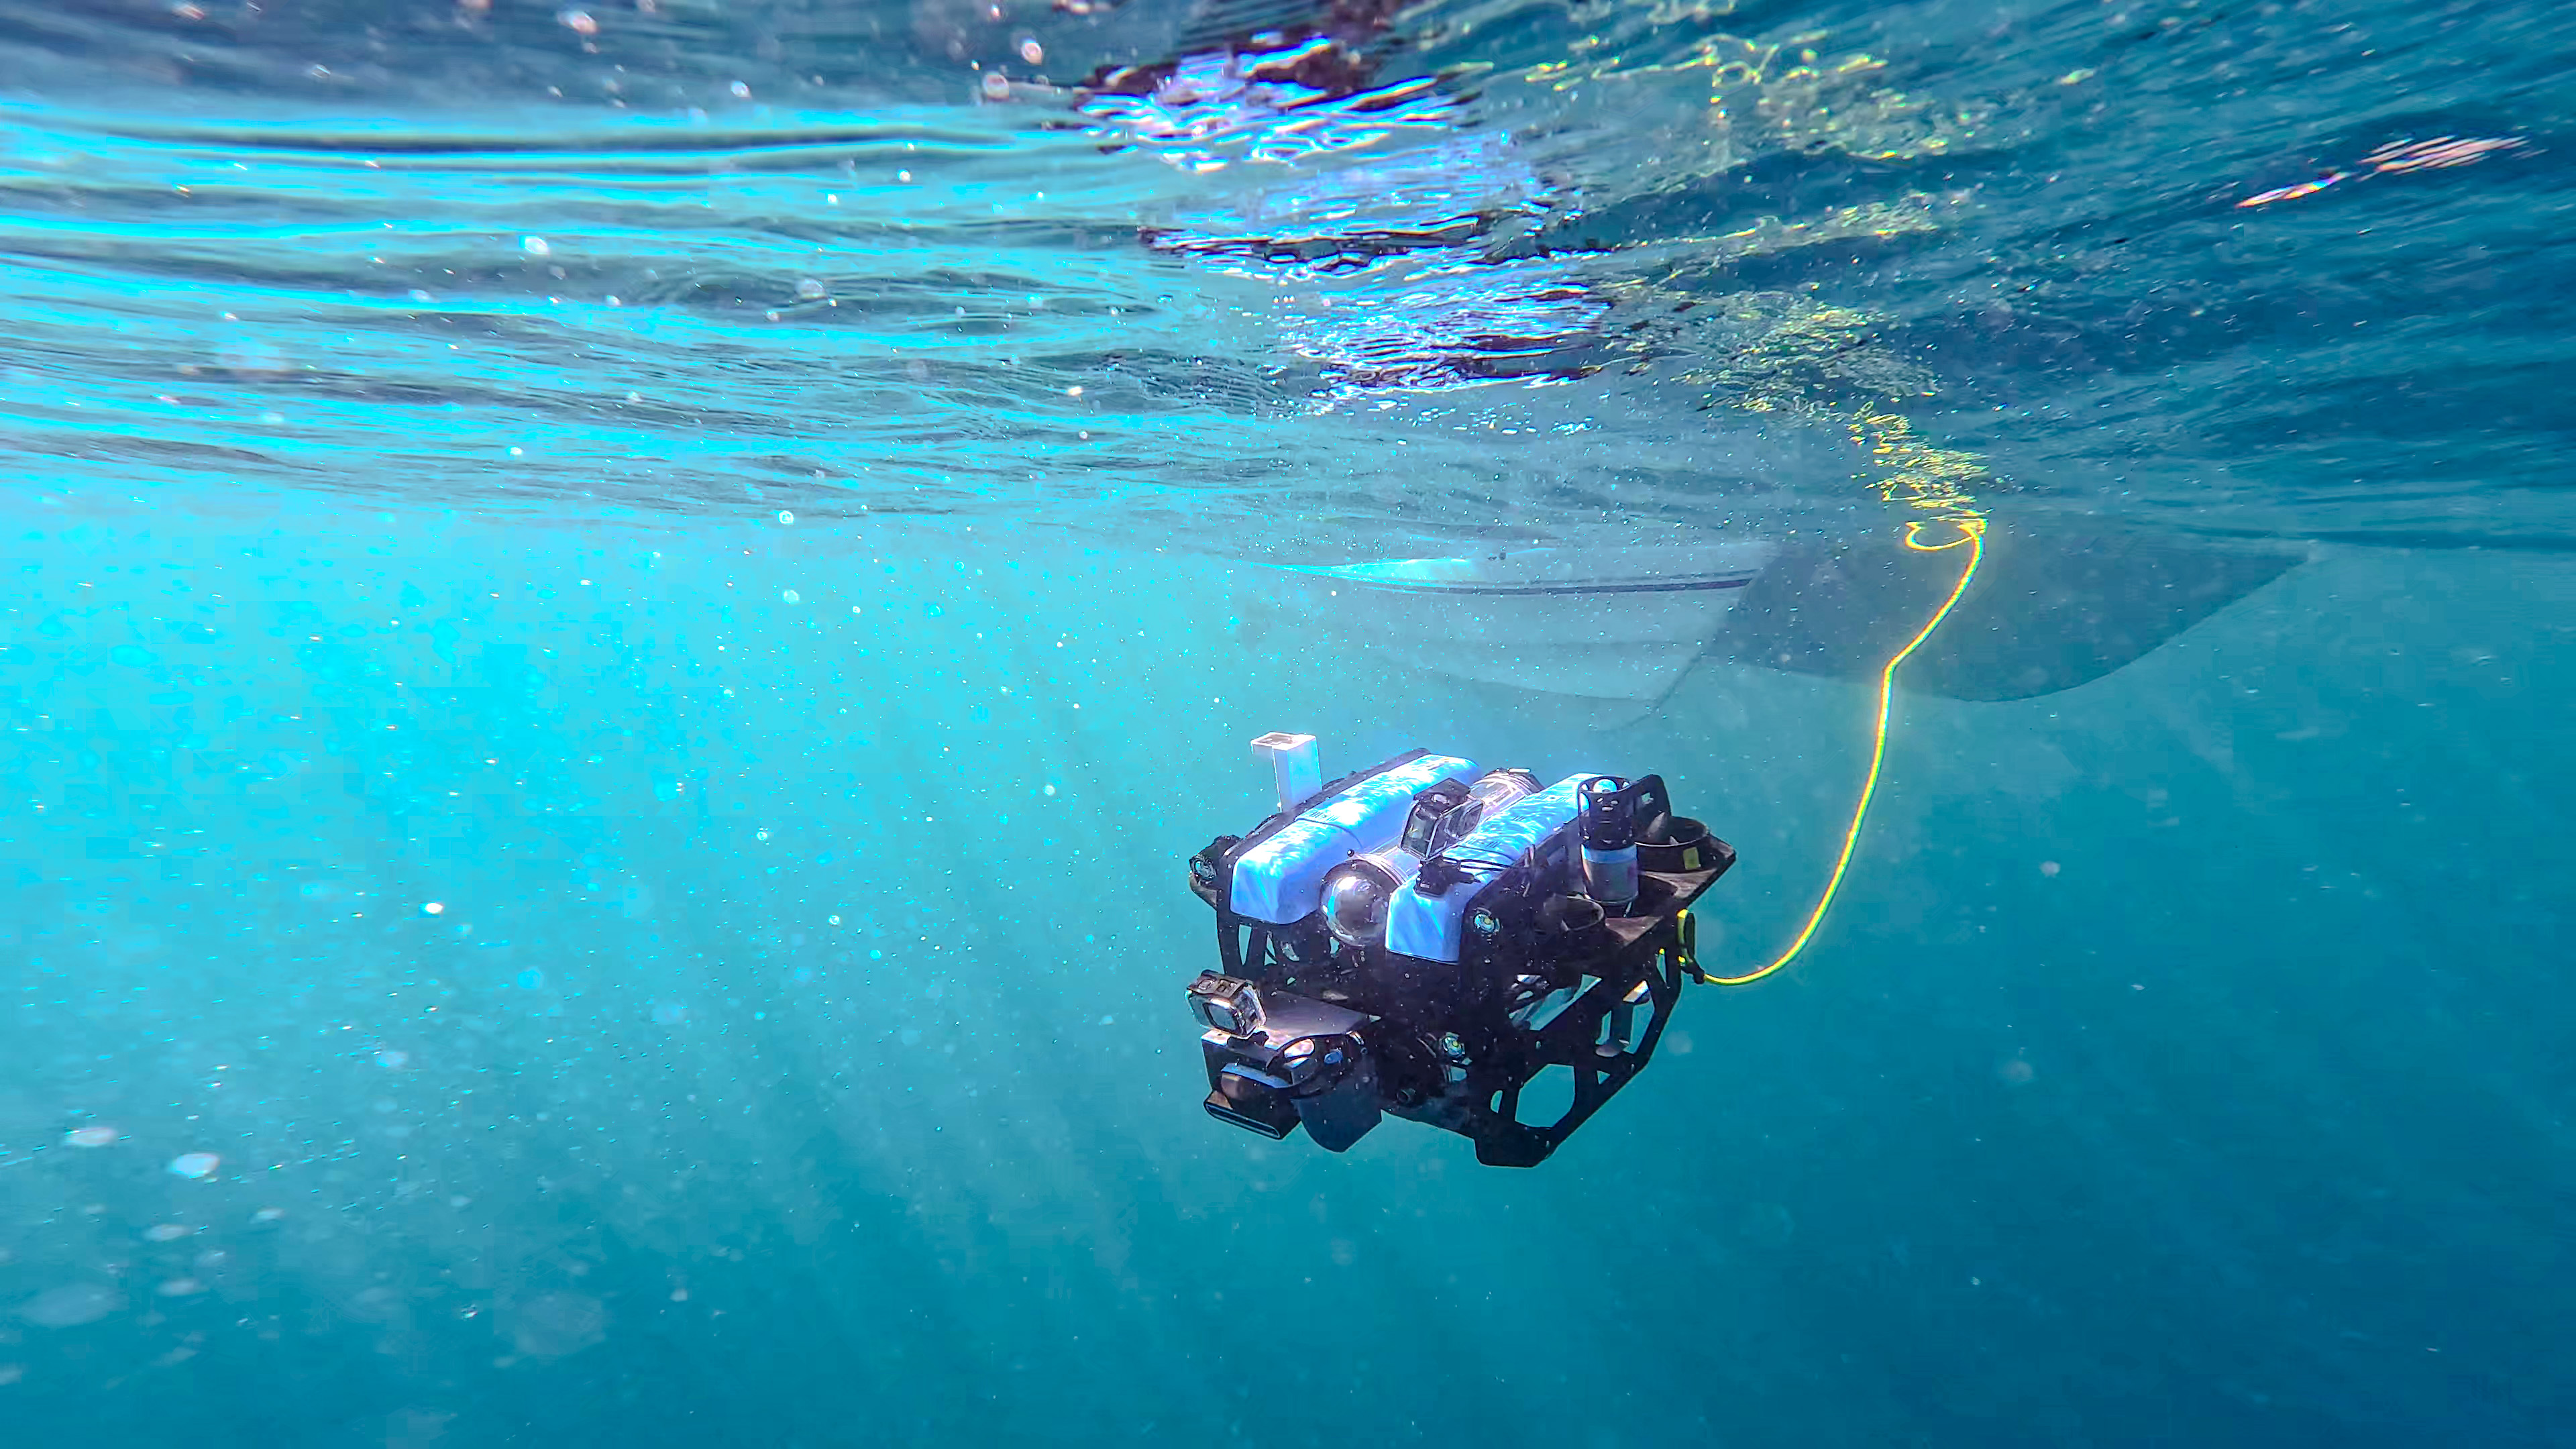
BlueROV2 Heavy
An underwater ROV for sonar, vision, mapping, and perception research.


Exploring the boundaries of autonomous systems with our custom fleet.
We have a number of robots that we use to test our algorithms, system development, and implementations.
An underwater ROV for sonar, vision, mapping, and perception research.
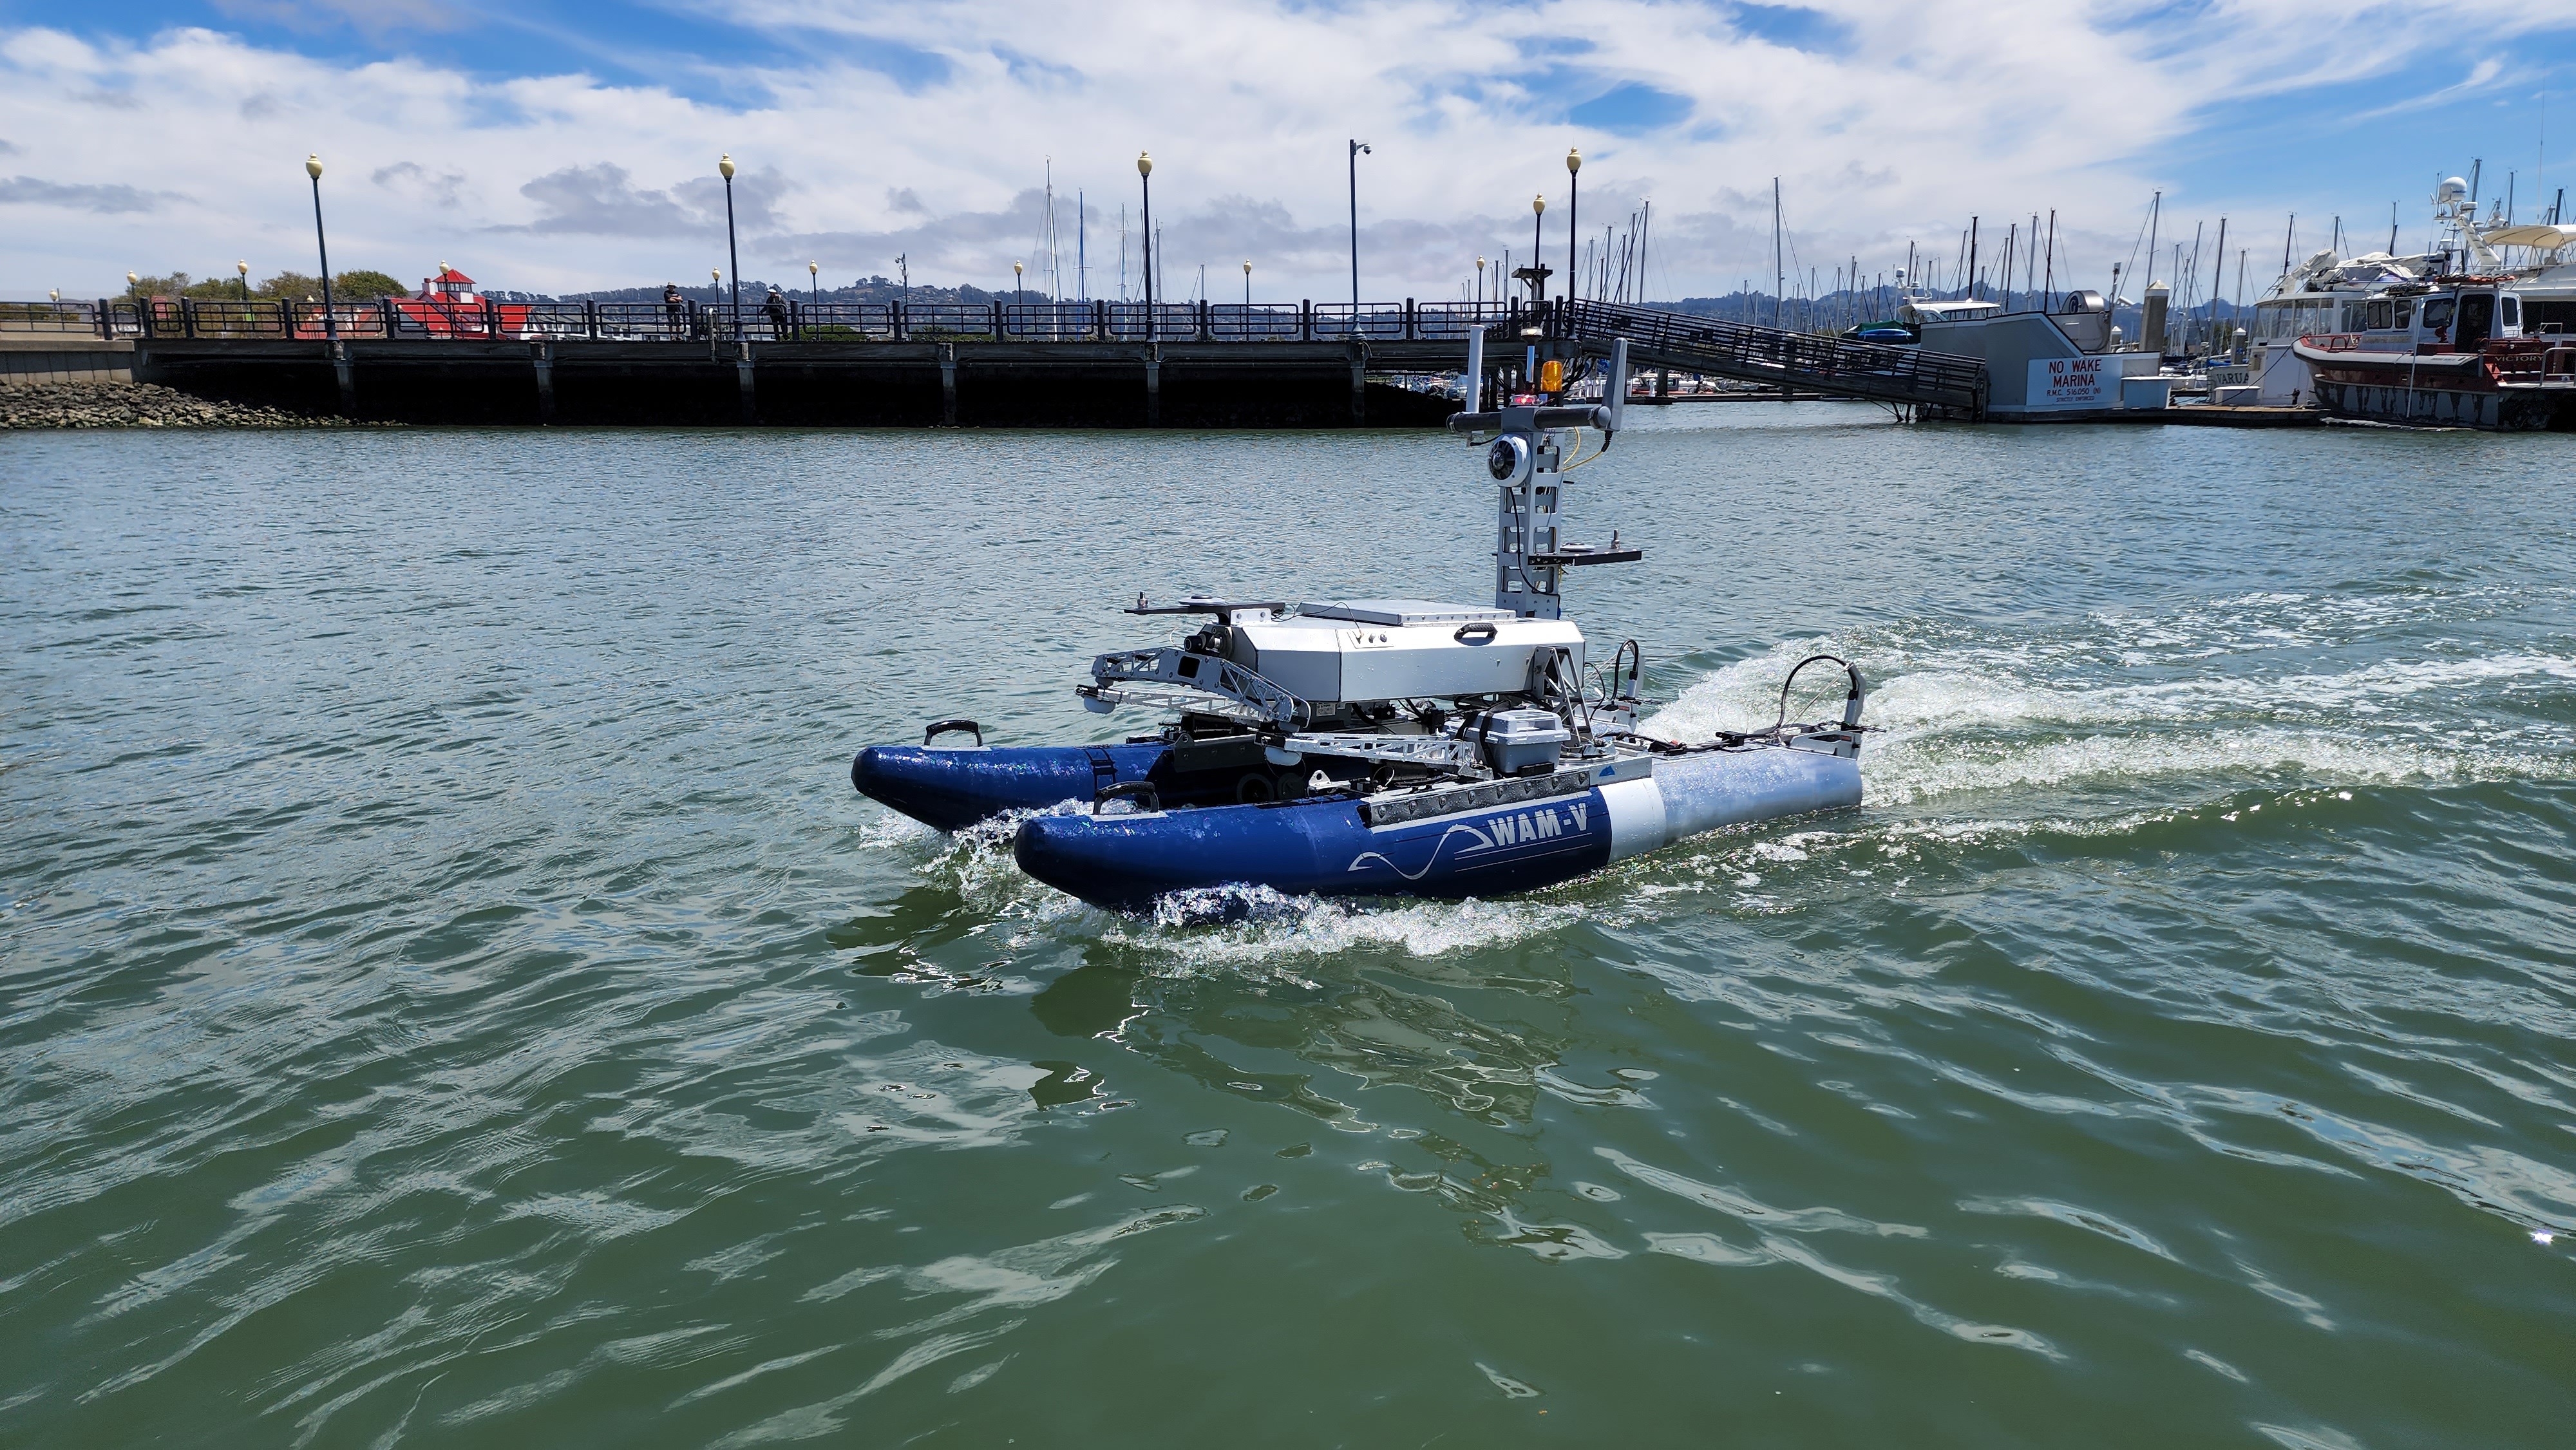
An autonomous surface vessel for bathymetric surveys and multi-agent mapping.
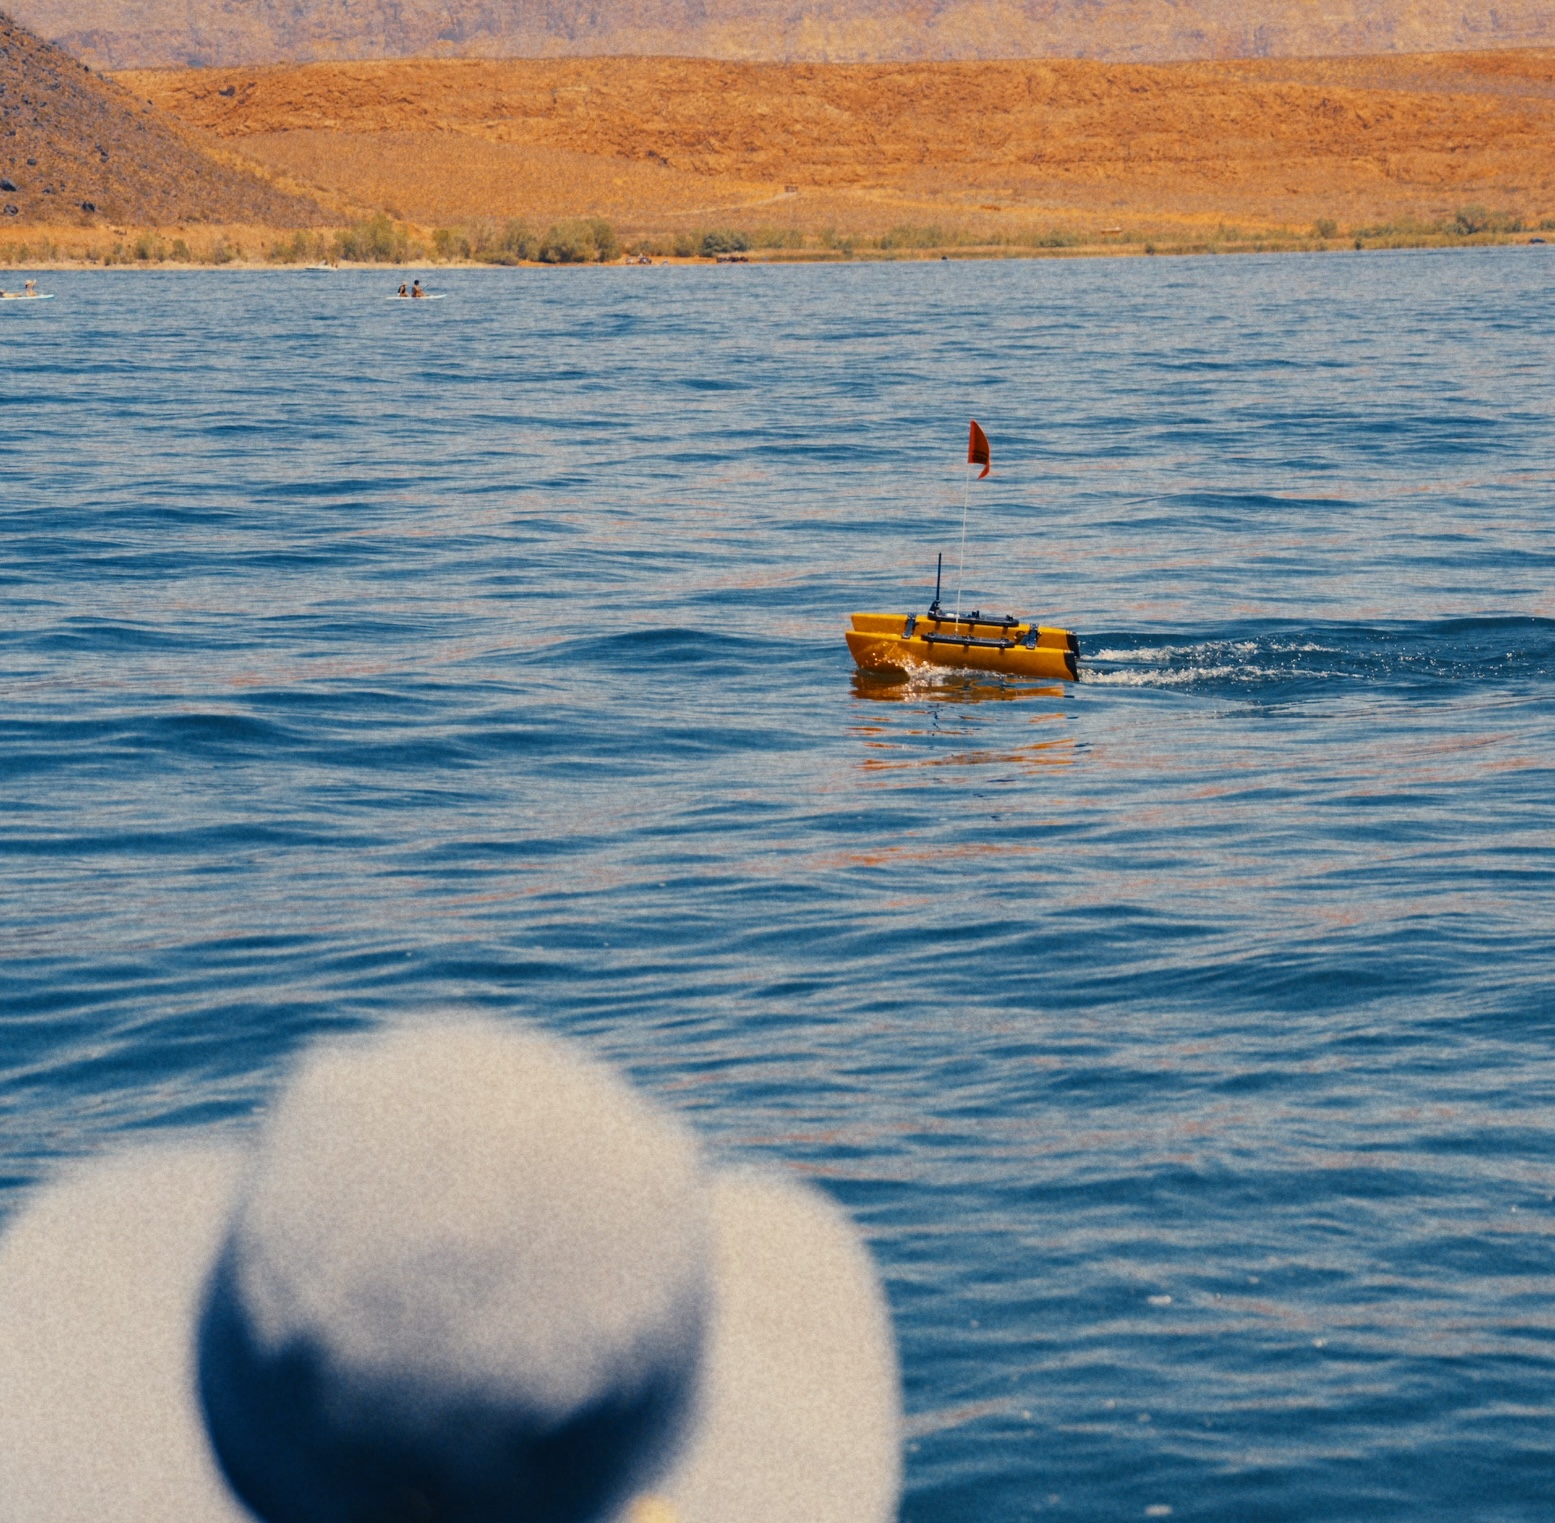
A compact surface vessel for autonomous surveys and field robotics research.

A low-cost underwater vehicle for training and cooperative autonomy research.
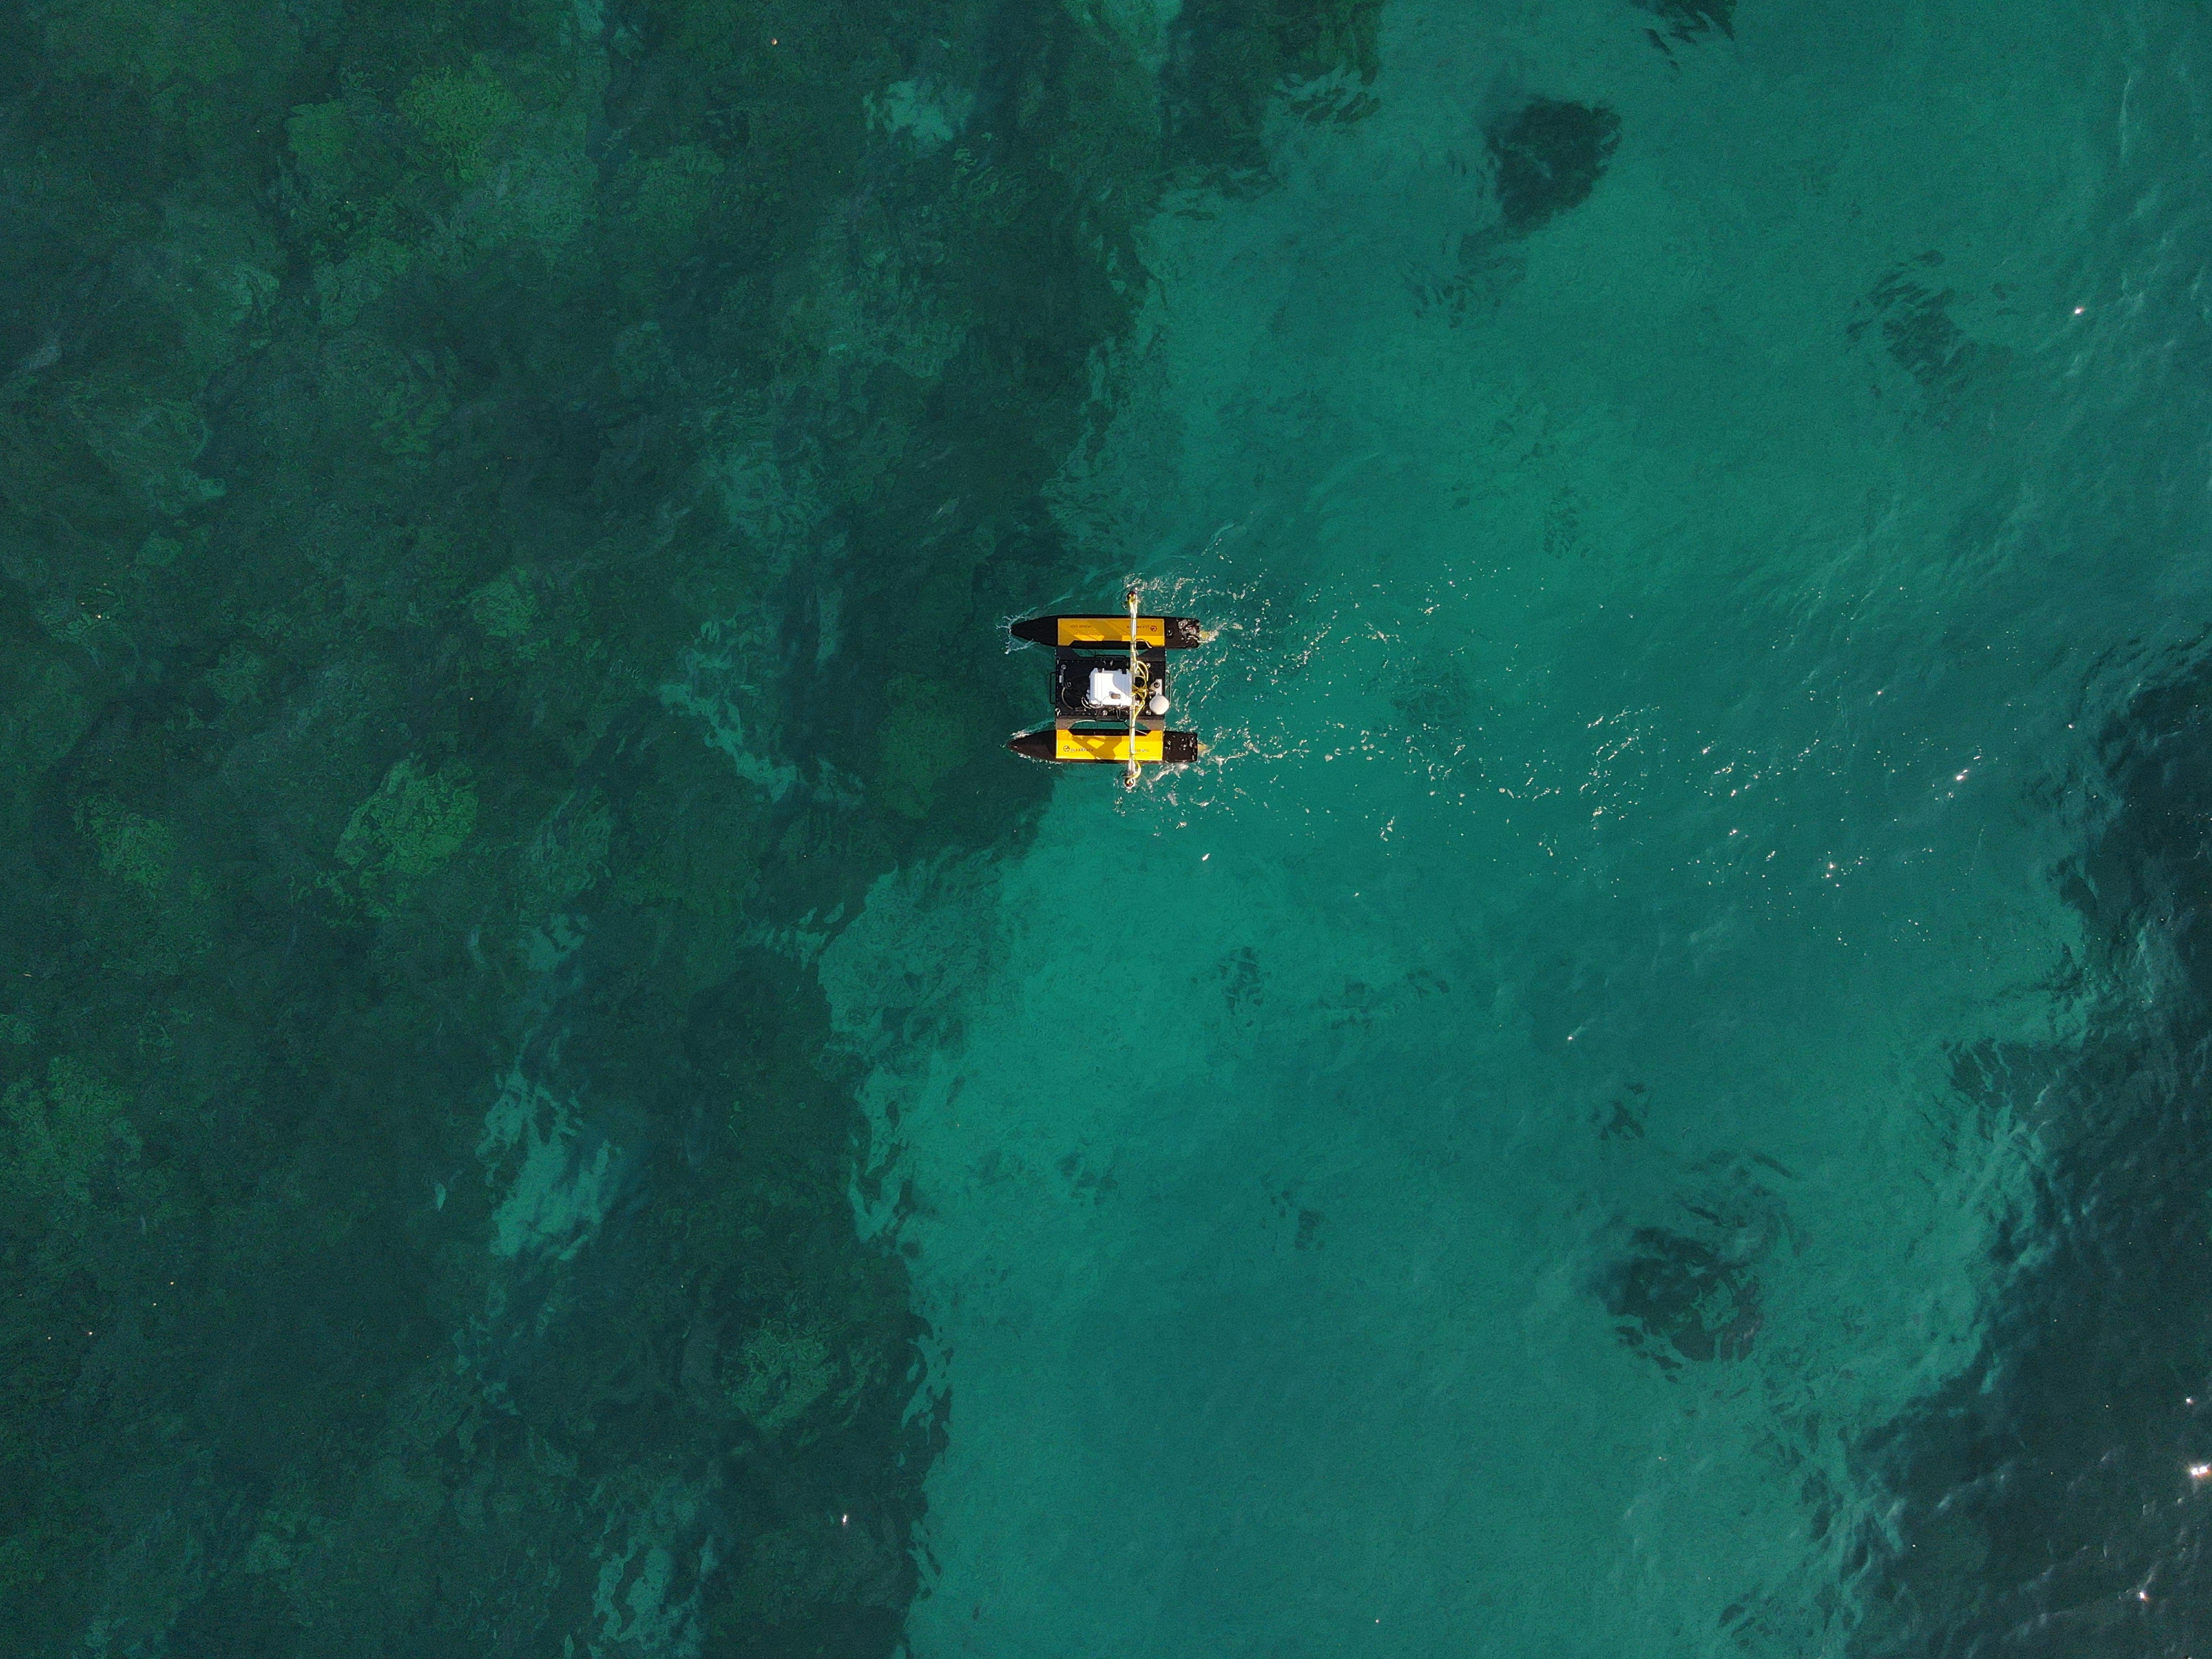
A surface vessel for marine imaging, reef surveys, and 3D mapping.
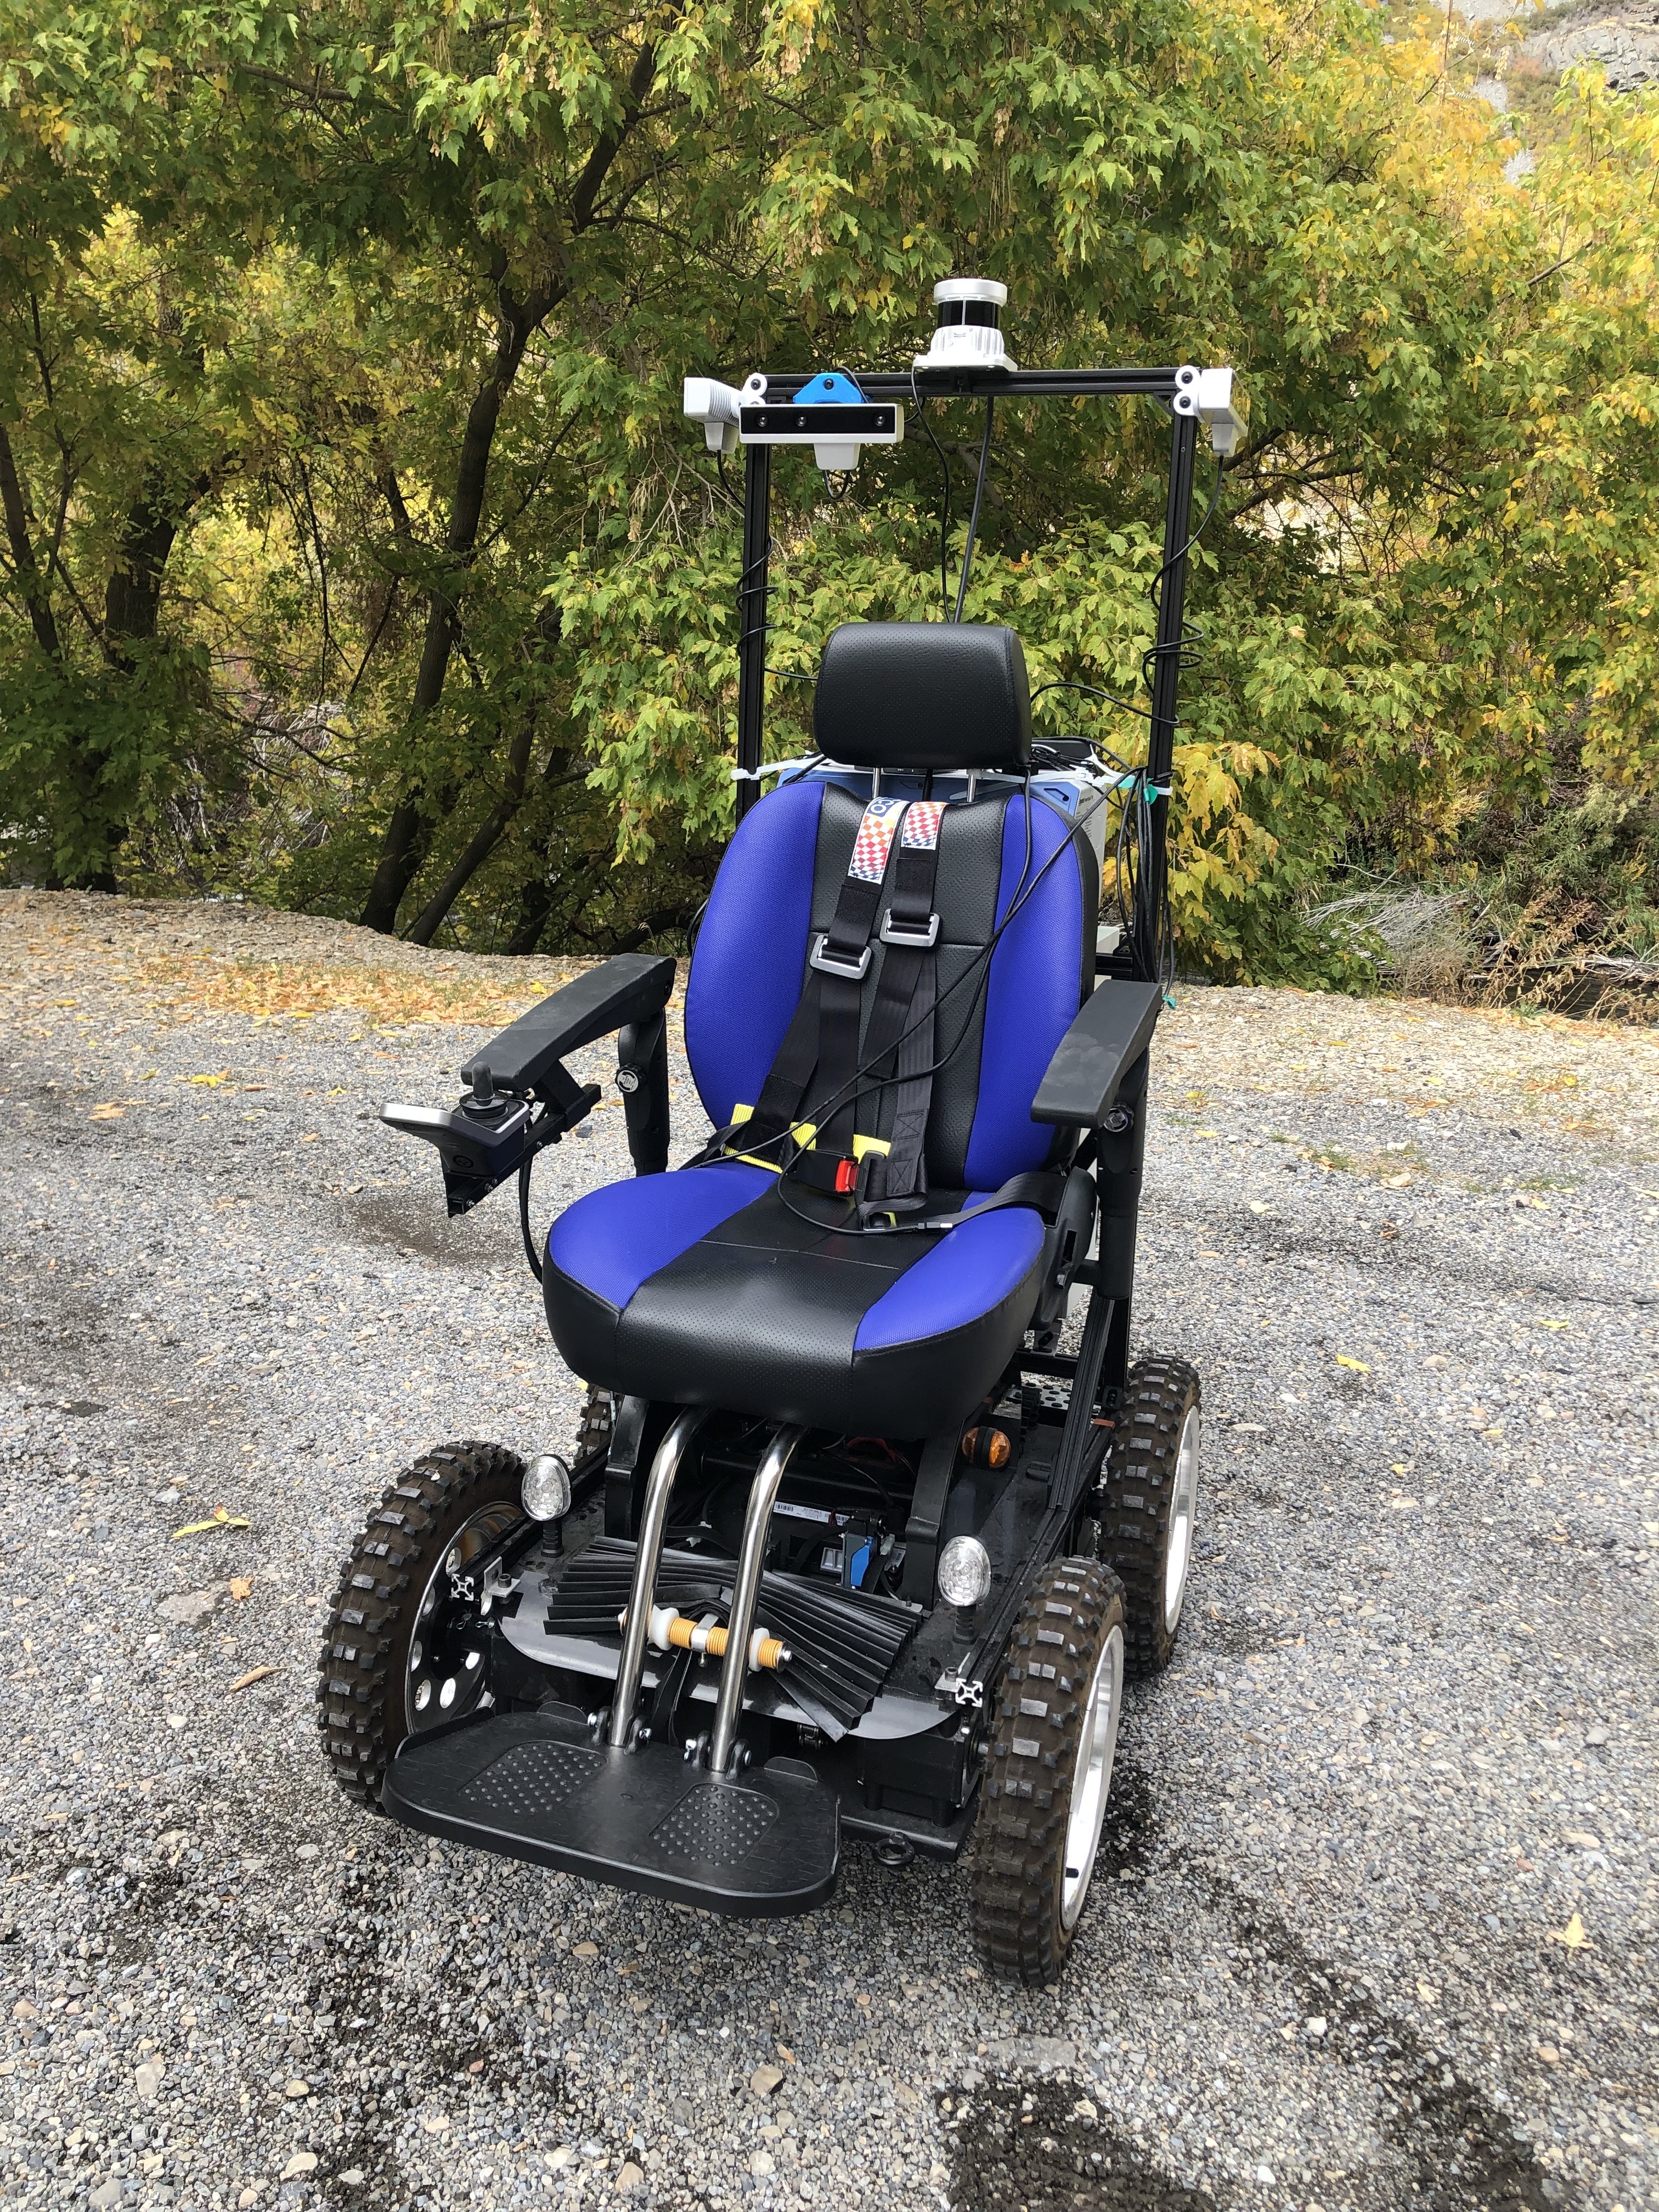
An all-terrain autonomous wheelchair designed to make more places accessible.
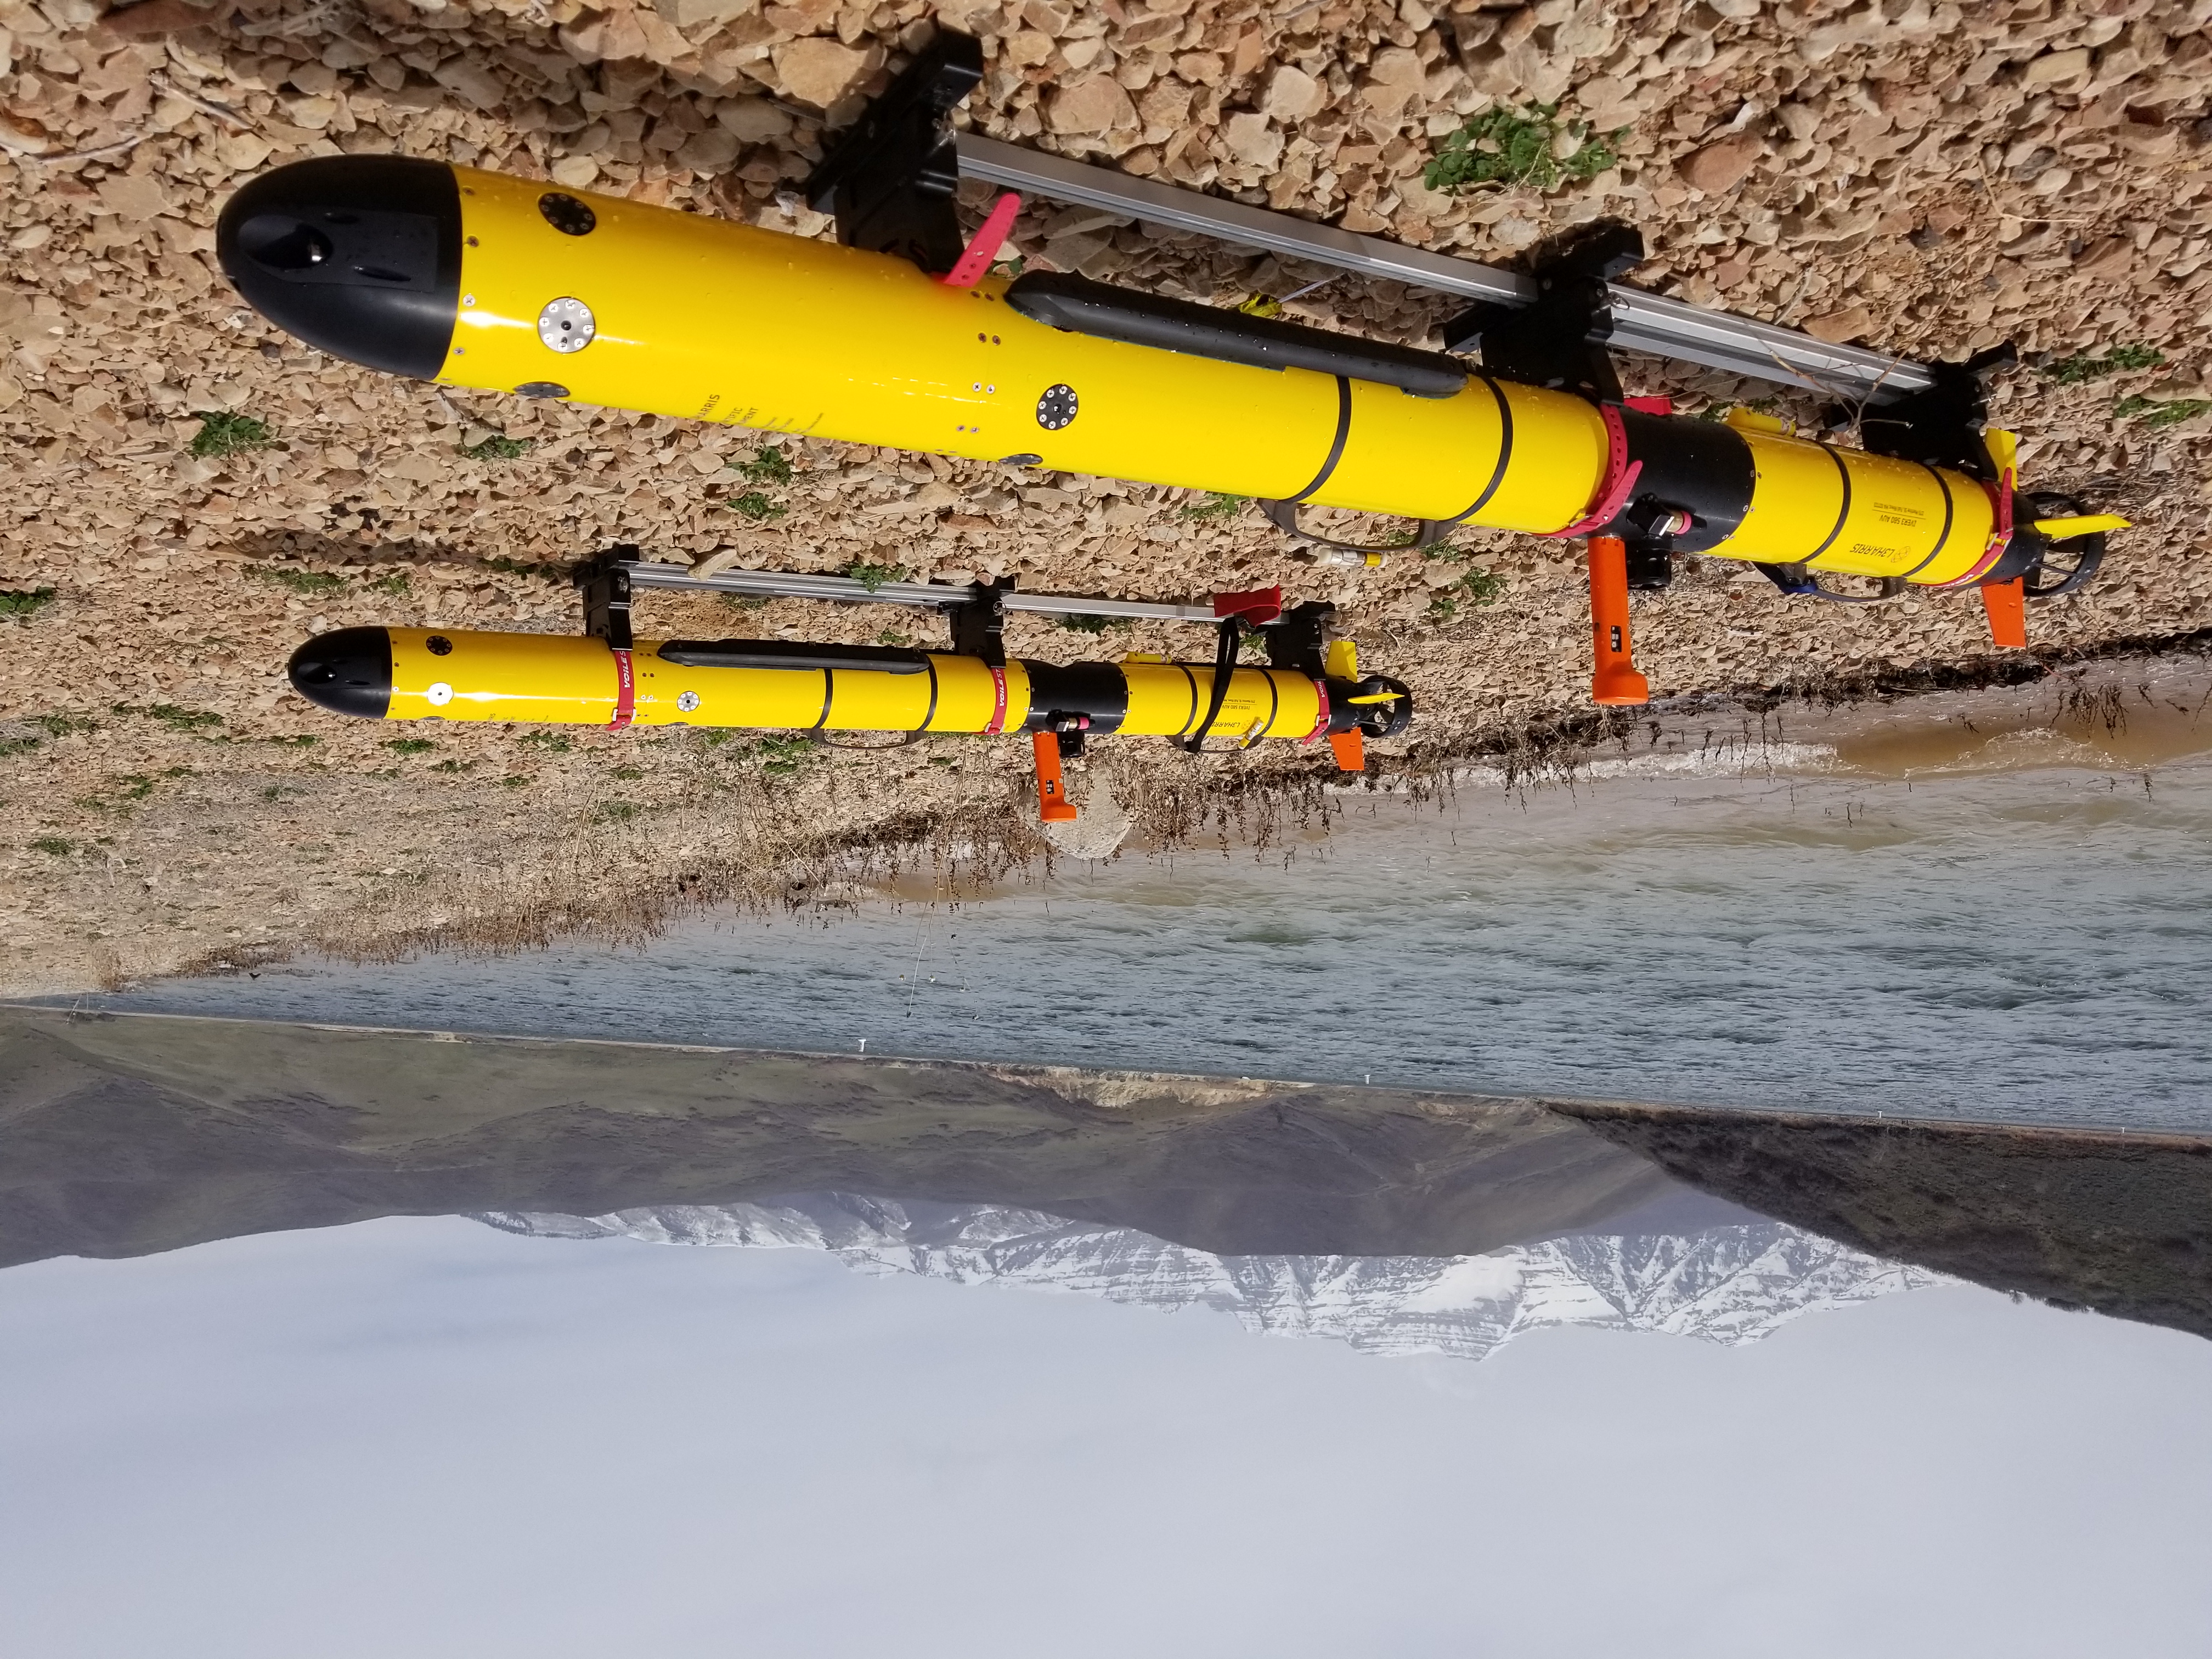
Industrial AUVs for subsea data collection and cooperative localization.
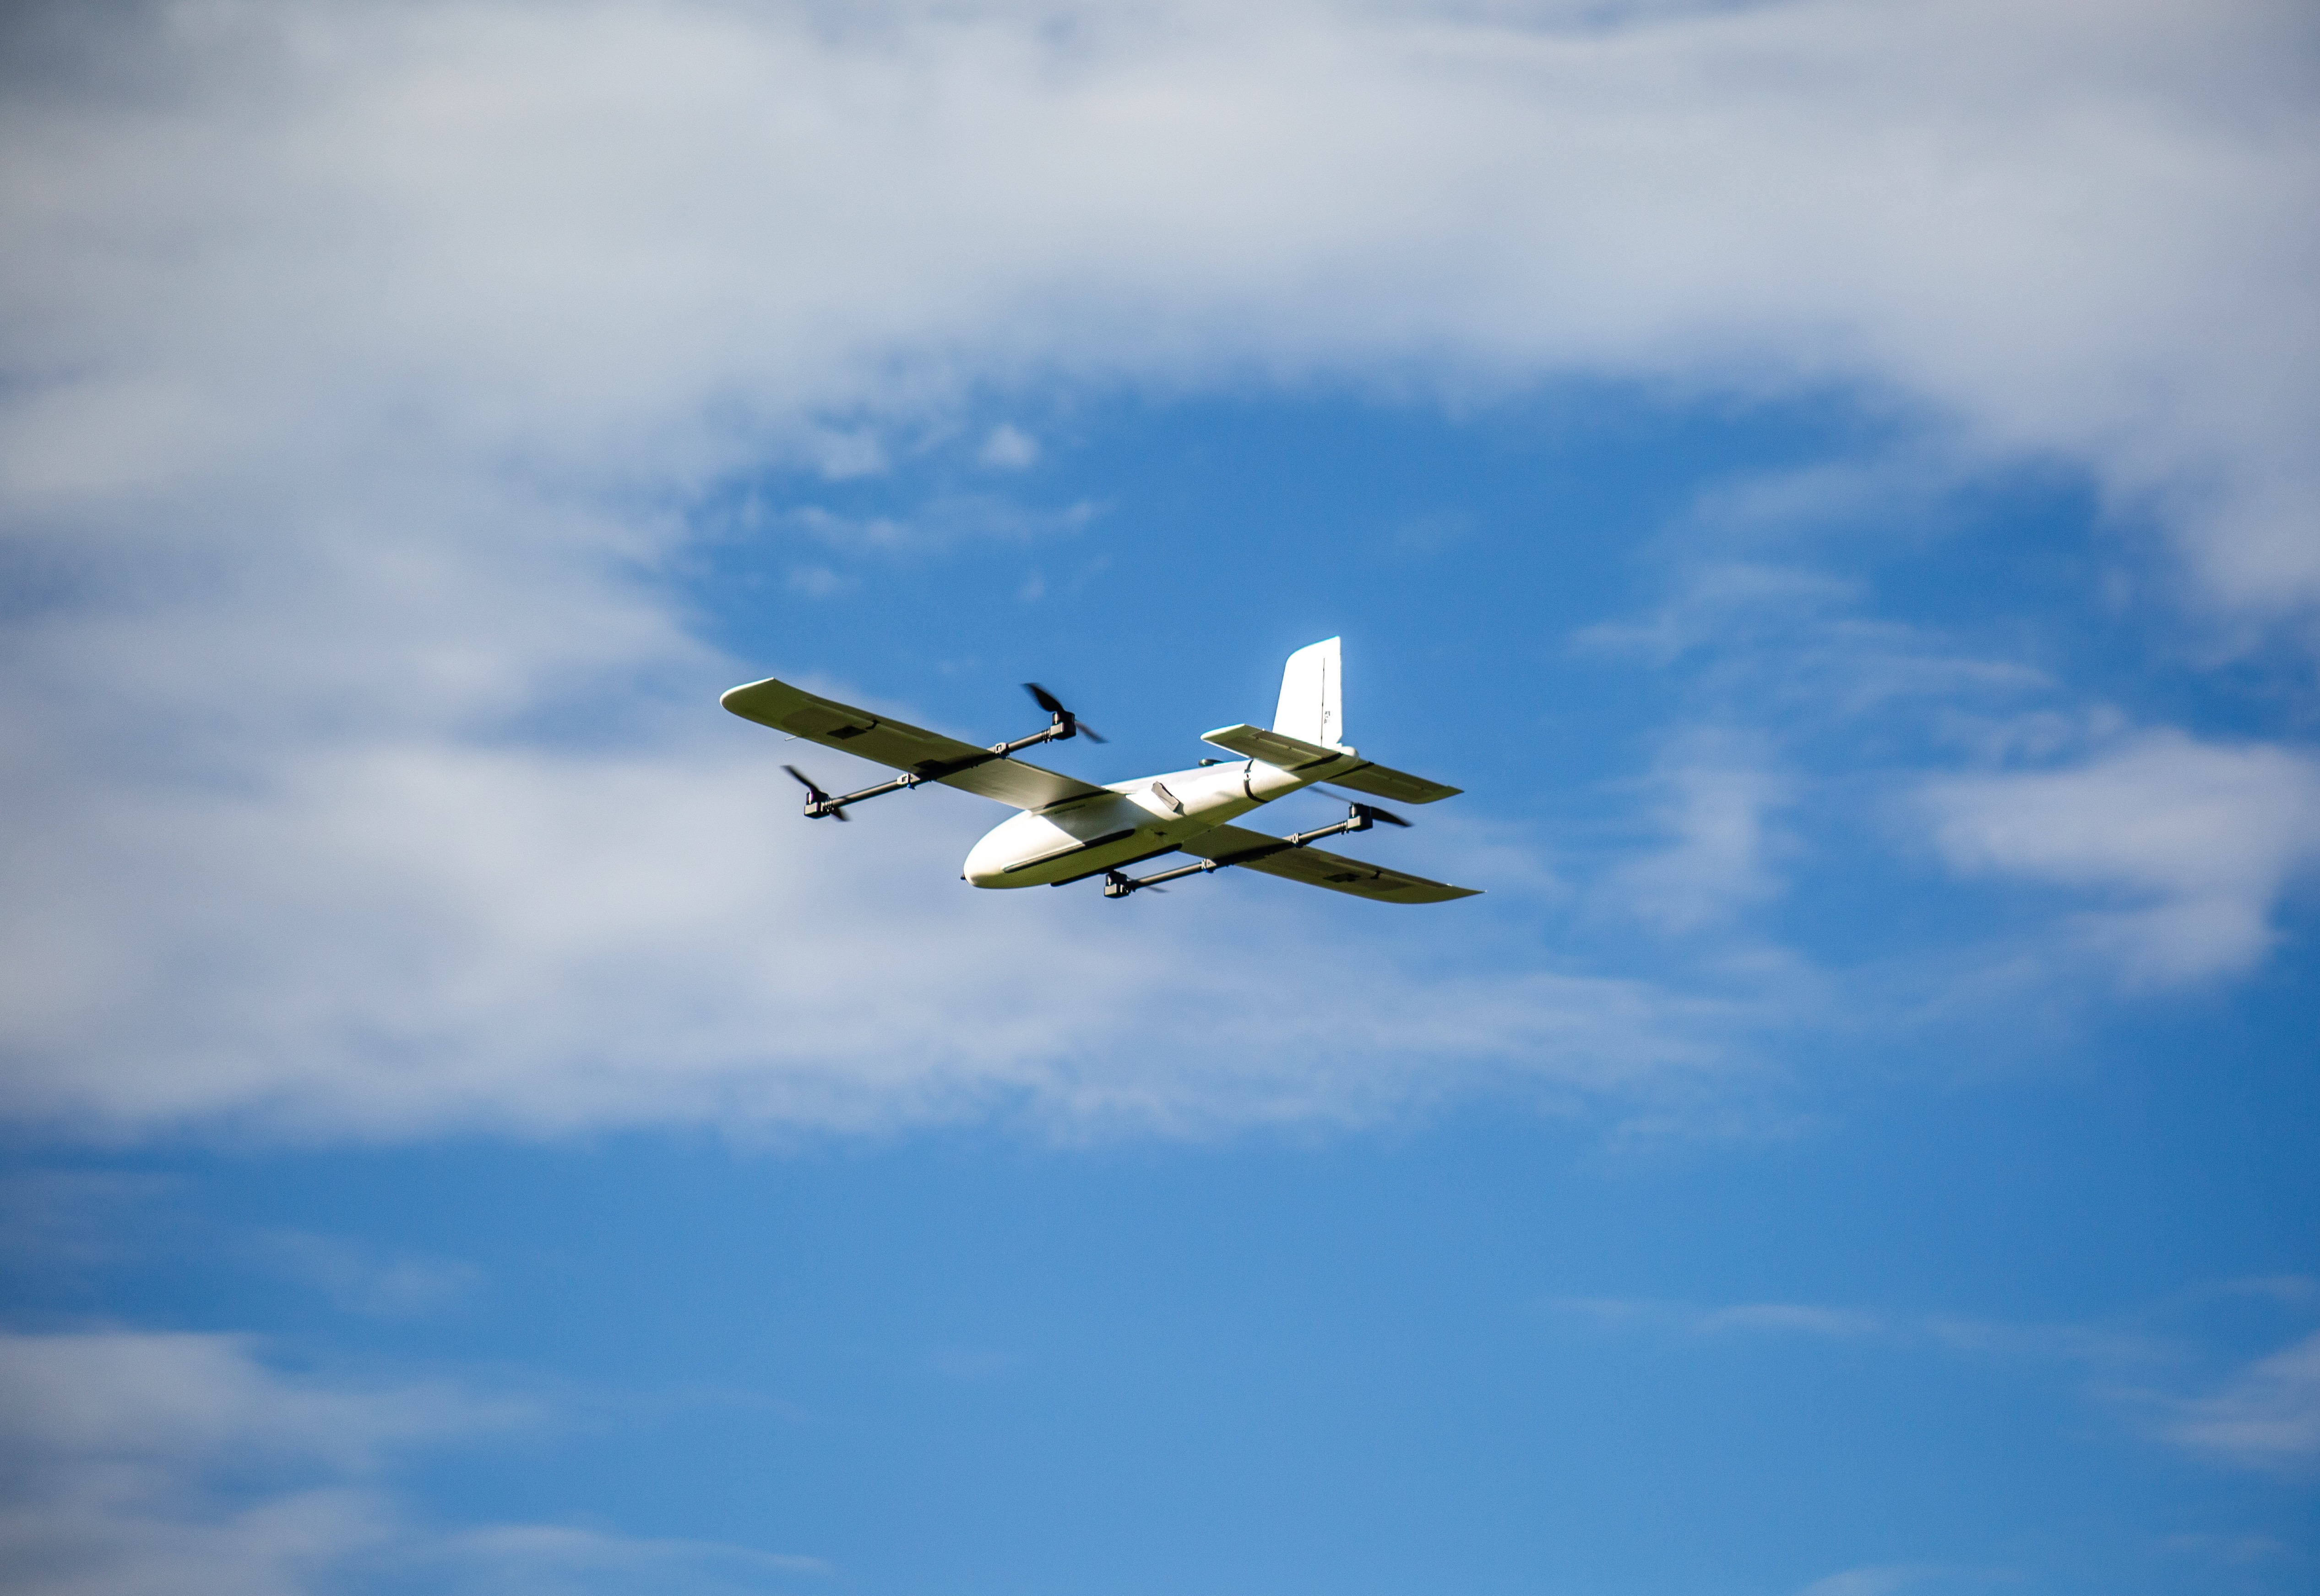
A long-endurance VTOL aircraft for aerial sensing and data collection.
Retired robots that paved the way for our current research.